
Smartphone Ego
First-person capture from an approved phone configuration. Scales to volume.
- Approved phone configurations and mounting positions
- Task briefs with initial and terminal state holds
- Video, motion signals, and device metadata
AuraOne / Human Data / Physical AI
Keep observed capture, machine enrichment and synthetic coverage distinct, with the relevant timing and permission records.
People record everyday tasks, with consent, from a phone or a wearable. Reviewers check every episode before it ships.
Capture, Synthetic Coverage and Machine Enrichment are scoped per program.
Robotics training data
Teleoperation data records a person remotely driving a robot through a task. Human-demonstration data records people doing the task themselves. Robotics teams use both to teach robots by example, a method called imitation learning.
AuraOne's Physical AI program covers both. Trained operators drive your robot through the task, or people perform it while cameras and wearables capture how. Reviewers check every episode before it ships, and observed, machine-enriched and synthetic data stay distinct. Glossary: teleoperation data
Real-world capture
People perform everyday tasks with consent. Trained operators capture the motion, timing, and failure context — not just the picture.
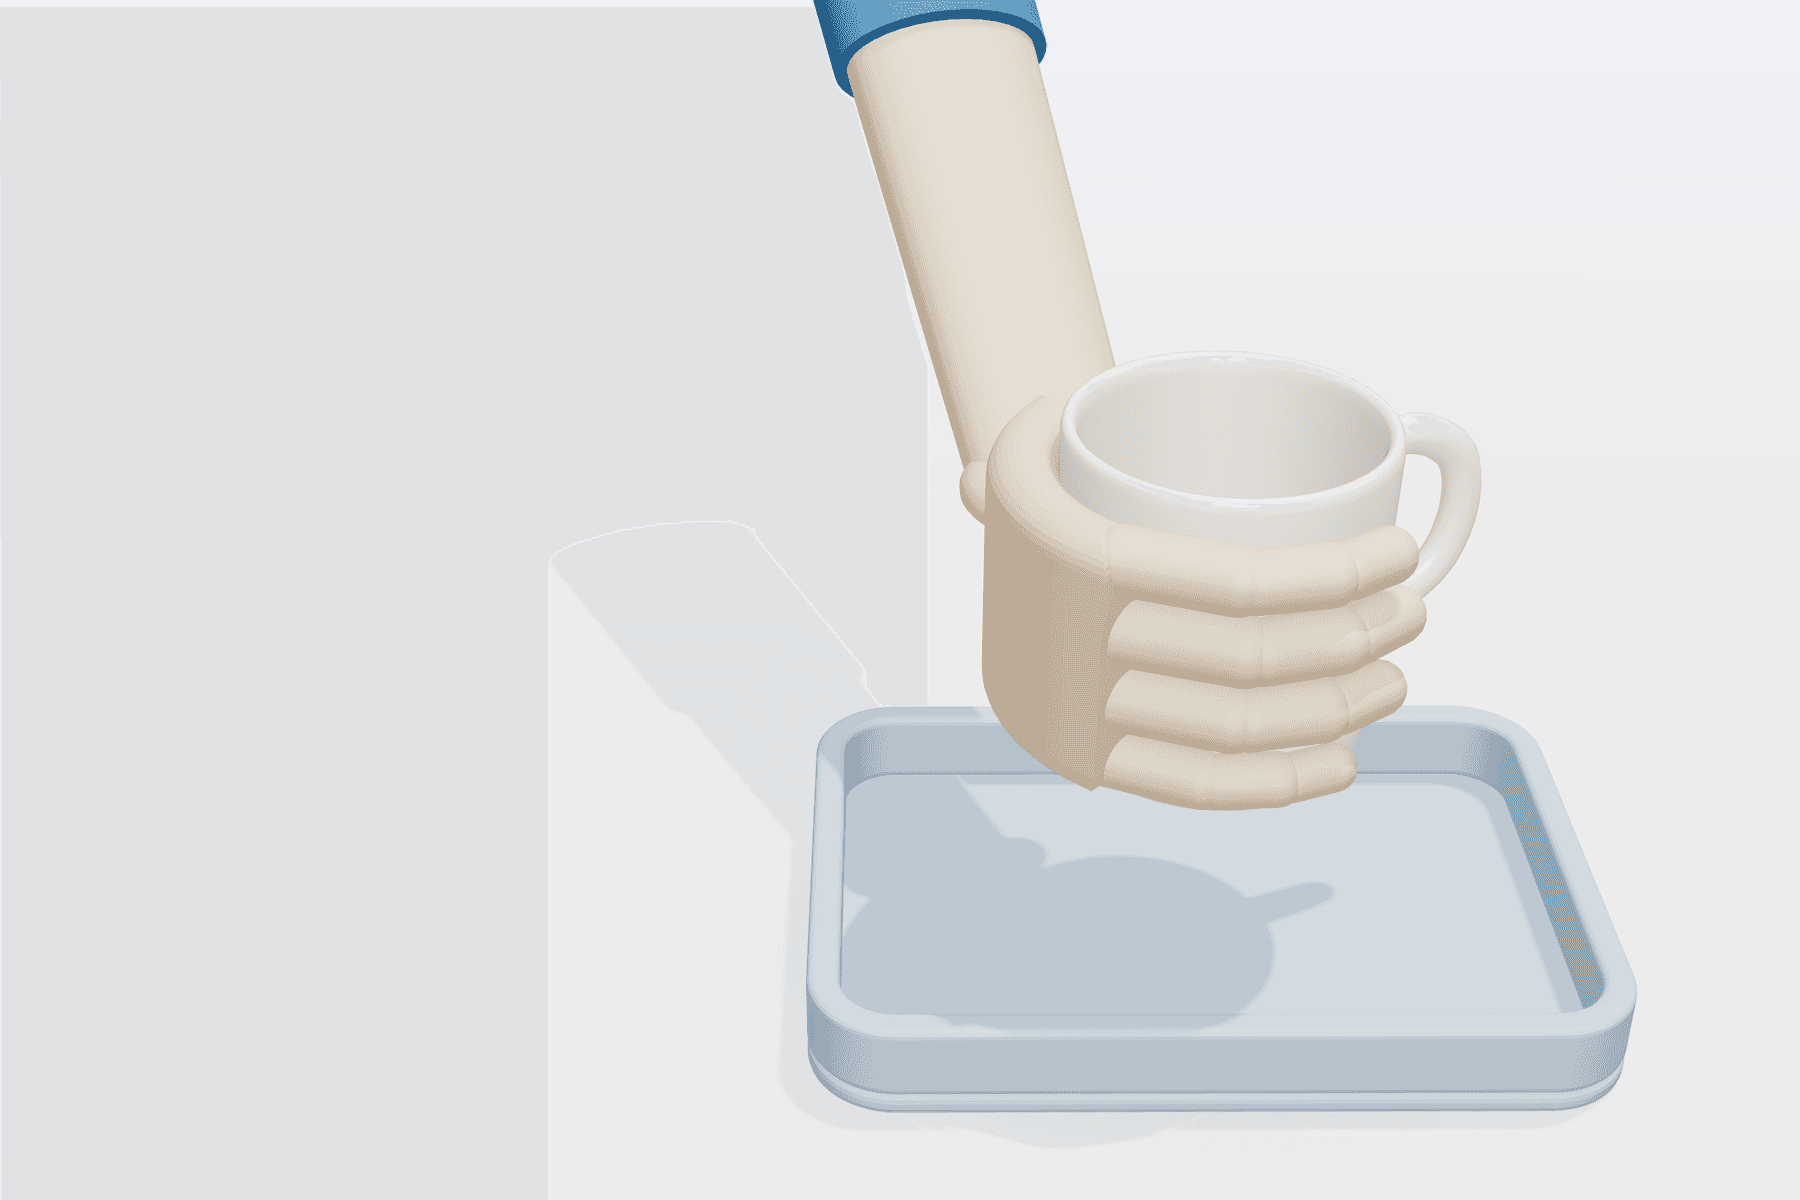
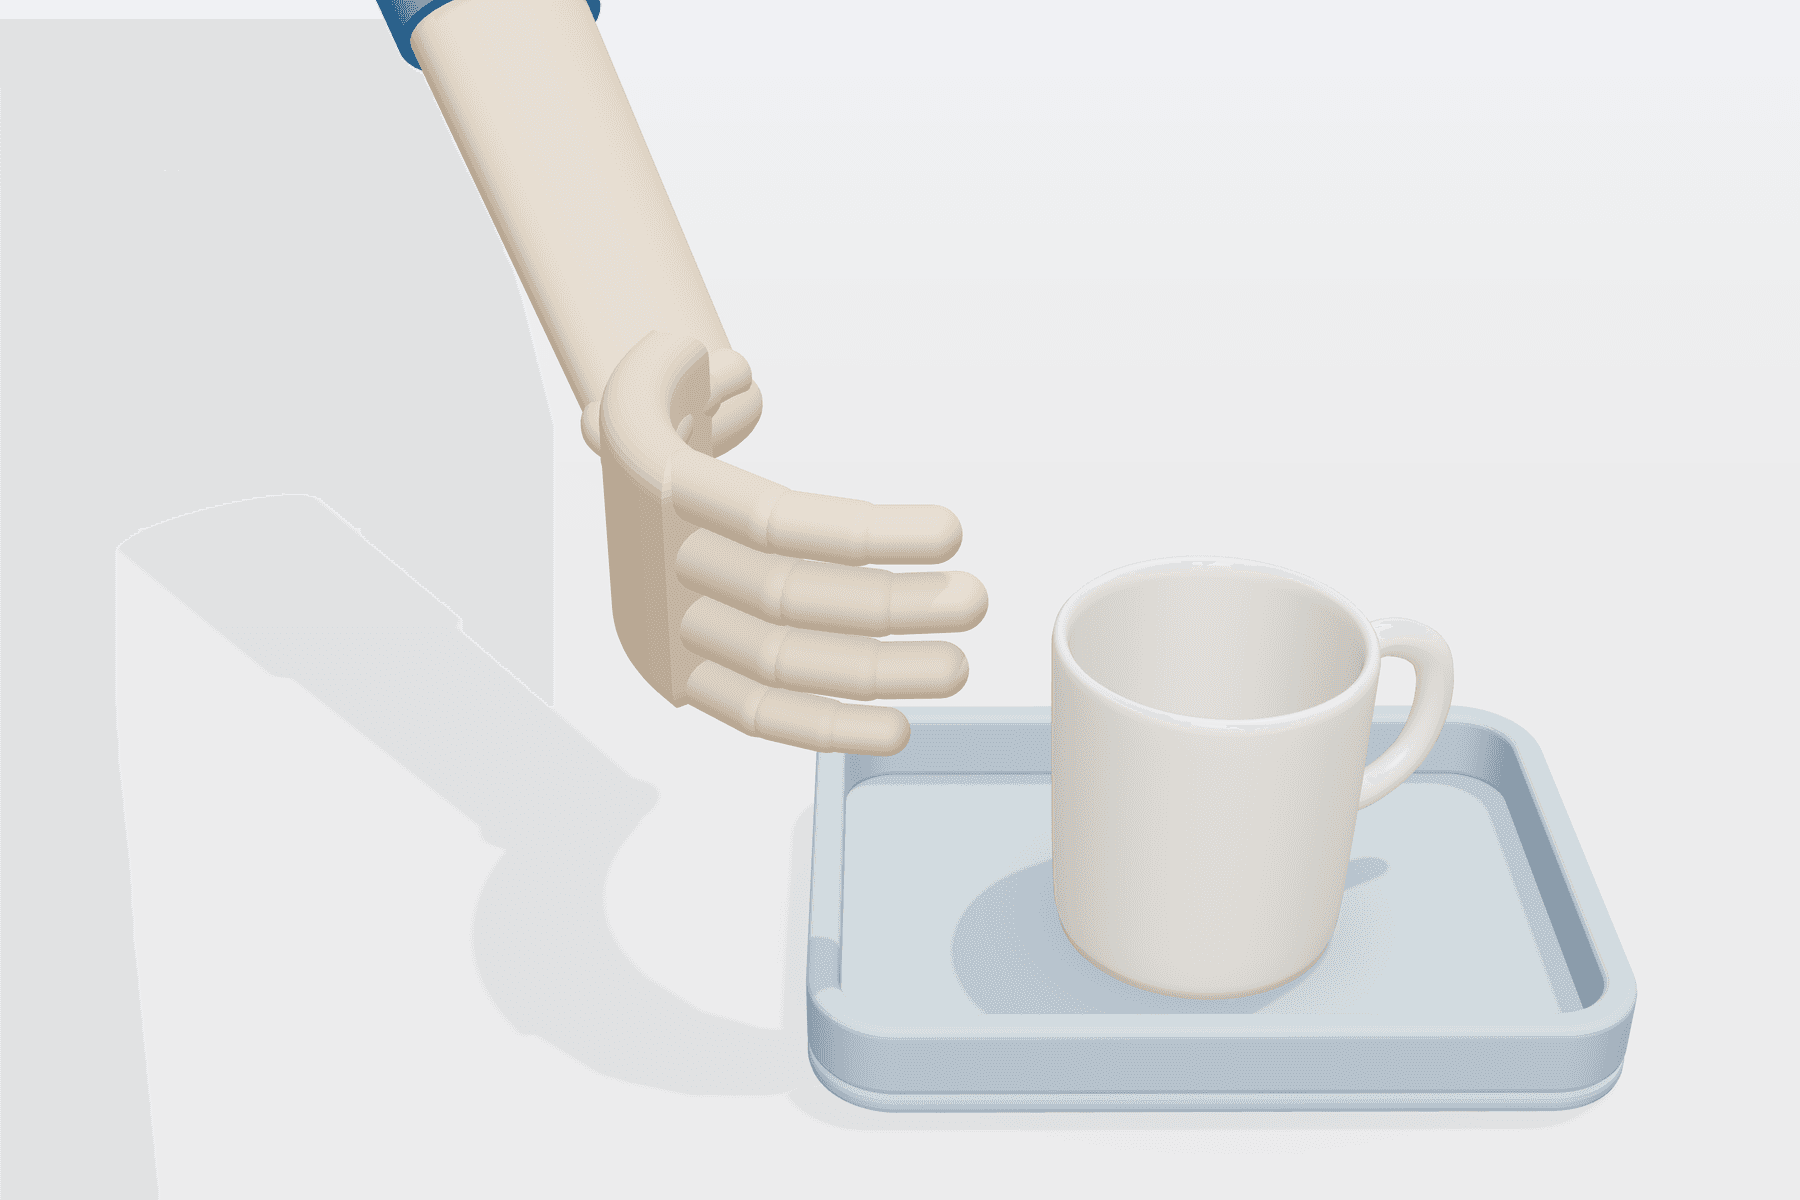
Three-phase episode segmentation
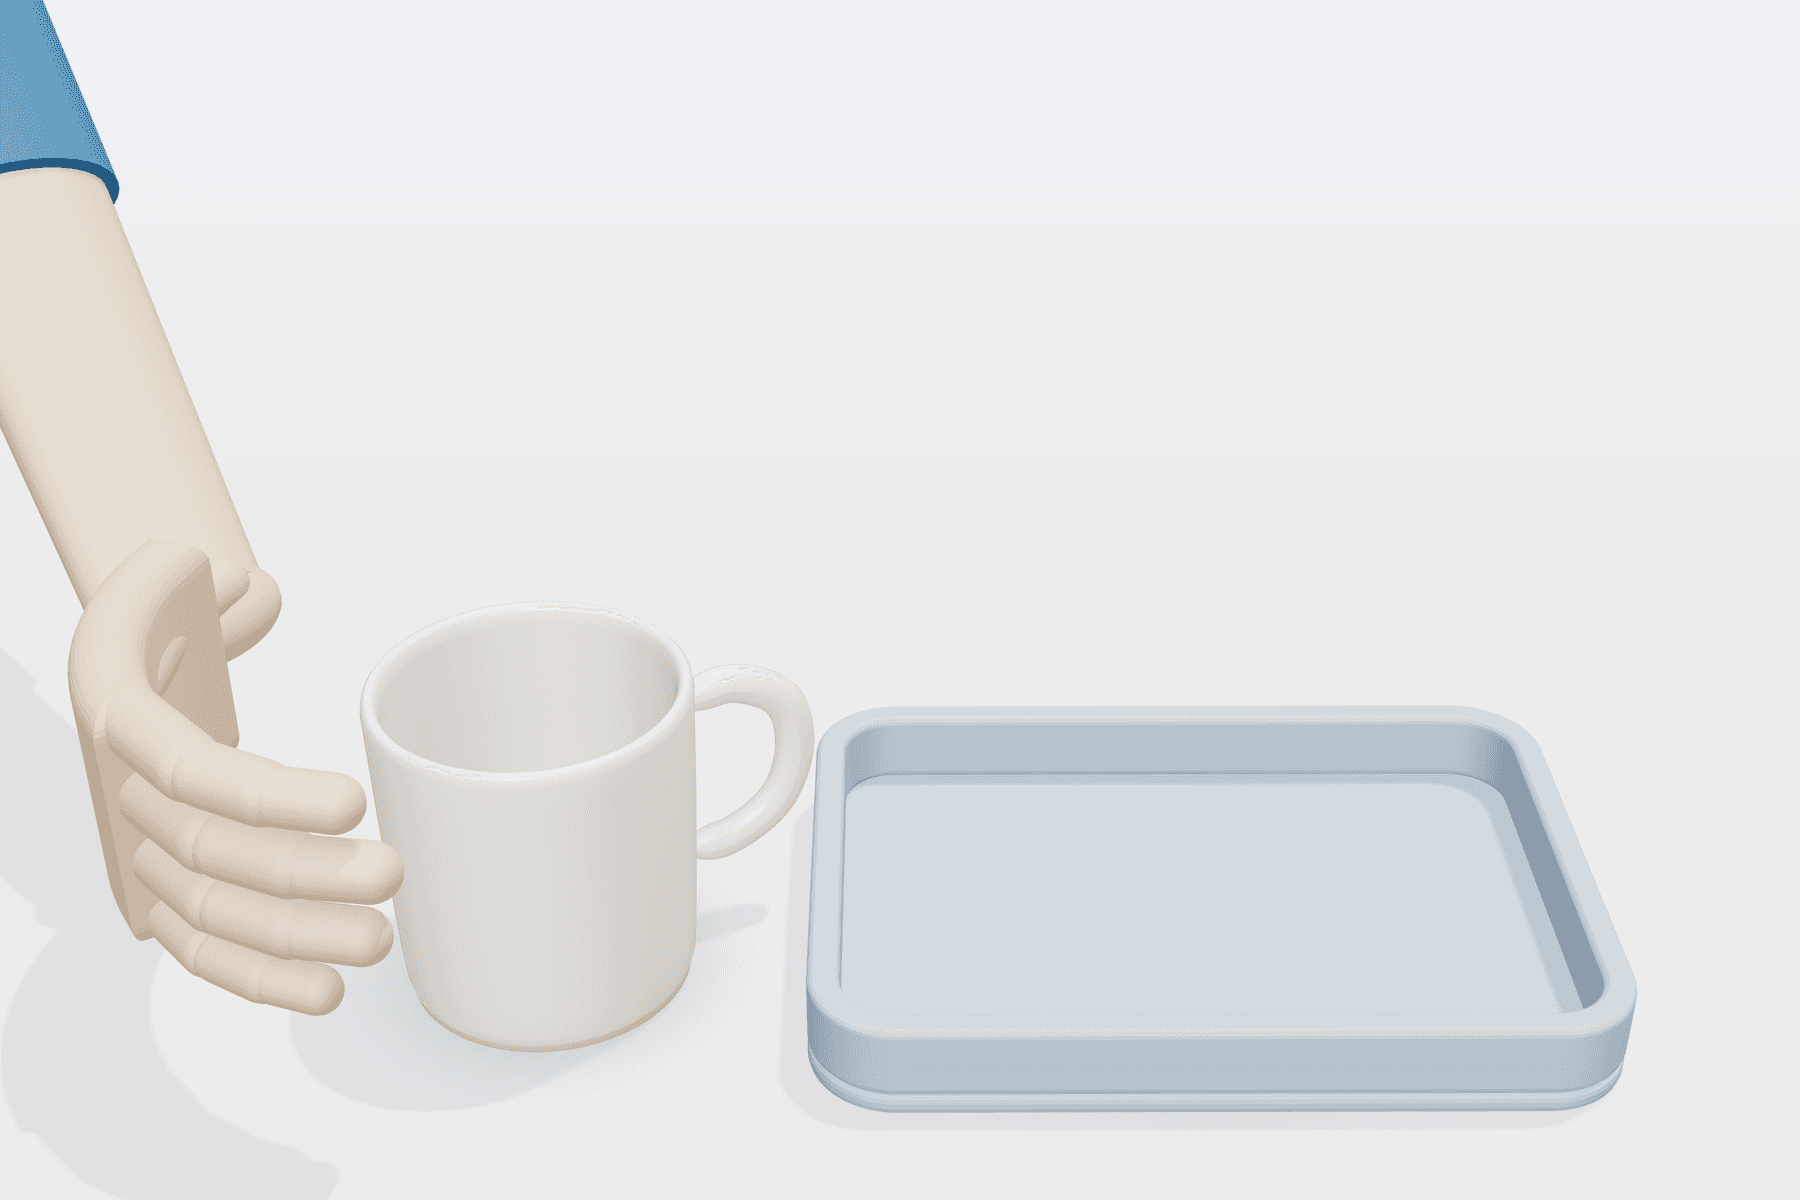
Before · 1 of 3
First-person capture from an approved phone configuration. Scales to volume.
Multi-view capture for tasks where hand visibility and timing matter.
Phone capture runs in Aura Capture, our human demonstration capture app. Programs that need mounts and cameras can use our robotics capture kits.
We record in the places your robot will actually work.
What you receive
Raw is never overwritten. Clean removes the dead time. Intelligence explains what happened.
SourceNever overwritten
The unchanged evidence, exactly as it was collected.
DerivedMapped from Raw
The accepted task content, with the dead time removed.
DerivedExplains Raw and Clean
The record that explains what happened, and whether it worked.
Your contract sets the exact scope. Managed robotics programs collect and review human demonstrations, then coordinate a monitored handoff; queued transcode, copy, or webhook work is not represented as delivered.
Beyond capture
Tell us the gap, or let AuraOne help identify it. Synthetic Coverage does not require Machine Enrichment. Machine Enrichment does not require Synthetic Coverage. Each capability must be contracted and production-qualified for its own program scope before use.
Combine real-world teleoperation and egocentric capture with local episode inspection, automated trajectory checks, and simulation-backed coverage.
Start from a buyer-defined or AuraOne-assisted gap to generate, validate, review, and deliver an immutable coverage batch.
Add machine suggestions to existing real episodes and route uncertainty through human review.
Enriched episodes can point to a measurable gap, and Synthetic Coverage can then fill it. The full loop is useful, but never a prerequisite for either capability.
Synthetic Coverage
When a real-world failure mode needs broader variation, define the scenario and target count to generate synthetic trajectories complete with a distribution report and lineage manifest.
A coverage program can begin from a buyer brief. Automatic gap discovery is not required.
When the program includes suitable source data and analysis, AuraOne can help identify measurable underrepresented conditions. The evidence and method stay attached to the gap.
Every synthetic expansion batch ships with its scenario specification, physics and sensor parameters, and a distribution report comparing synthetic rollouts against your real-world failure episodes.
Machine Enrichment
Each machine suggestion carries a confidence score and its source episode. Confidence thresholds route questionable outputs into an append-only human review record with preserved machine authorship. Automated kinematics and trajectory checks run across every episode file alongside multi-camera visual review.
Output classes are configured for your program’s sensor suite and evaluation schema.
Existing annotation, queue, persistence, and review machinery carries machine suggestions into an auditable human decision.
Every automated kinematic finding is logged with its exact frame range and sensor channel so reviewers can jump straight to the anomaly. Enrichment can run independently or alongside Synthetic Coverage.
Verification & provenance
Every artifact in a physical-AI program is tagged with its origin so your team never mistakes a machine flag or a synthetic rollout for a recorded episode.
Coverage, quality, review, rights, provenance, format, and delivery evidence meet the contracted criteria.
An authorized buyer accepts the immutable batch. This completes the normal commercial delivery path.
If the customer evaluates the batch in a model or robot, AuraOne can attach the reported result without presenting it as AuraOne-controlled proof.
Only a controlled, authorized environment can produce this evidence class. It is optional and outside normal batch completion.
Each outcome depends on the scope your program agreed to.
| Outcome | Work | What you receive | Program fit |
|---|---|---|---|
| Train a manipulation policy | Collect successful demonstrations of one skill across varied objects and settings. | Episode count, task coverage, and accept rate. | Coverage applies to the environments and objects in the brief. |
| Build a failure set | Keep the attempts that went wrong and label how they went wrong. | Failure labels, source episodes, and reviewer rationale. | Reuse depends on your rights scope and retention policy. |
| Benchmark a robot release | Replay a fixed episode set against a new policy and compare outcomes. | Held-out episodes, scoring criteria, and per-episode results. | Results apply to the scoped episode set and criteria version. |
| Expand into a new environment | Run the same skill in homes, warehouses, or retail floors. | Environment coverage, location consent, and privacy zones. | Each site requires its own consent and privacy review. |
Start with the gap
Tell us what is missing, show us the real episodes that need structure, or scope both. We will define the applicable capability, evidence boundary, and acceptance criteria with you.
Guides